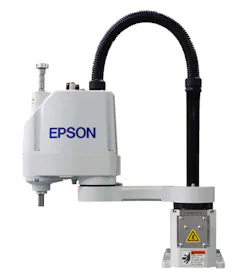
Implementation of robots across industry has been on a break-neck pace over the last few years. Evidence of this can be seen in research from the Robotics Industries Association, which shows that, during the first quarter of 2017, “an all-time high total of 9,773 robots valued at approximately $516 million were ordered from North American robotics companies.” This level of sales follows the record-breaking performance of 2016 during which “34,606 robots valued at approximately $1.9 billion were ordered in North America, representing growth of 10 percent in units over 2015.”
Click this link for more robot market information.
With so much activity on the robotics front, chances are good that you are looking to add to your robot inventory or begin seriously incorporating robots into your production processes.
In either case, how can you be sure that you’re making the right choice of robot and that you’re working with the best vendor for your application?
According to Rick Brookshire, senior manager at Epson Robots, there are six key aspects to examine to help guide you through your robot and vendor selection process.
- What do you want the robot to do? Yes, this is as straightforward as it sounds.
- Next, have at least a rough idea of the layout for the robot workcell.
- Determine what level of placement precision is required. This is where information about your manufacturing tolerances will be applied to your robot selection.
- In addition to your precision requirements, be sure to include your throughput requirements, such as how many parts per minute need to be produced.
- Don't forget to consider peripheral devices that may be part of the robotic workcell—devices such as visions systems, feeders and conveyors.
- Determine what kind of ROI you need for your project to be considered successful. “Some robot projects can achieve ROI in as little as six months,” said Brookshire, “although it’s important to realize that ROI can vary tremendously depending upon the application.”
Beyond these core considerations, I asked Brookshire if there are any vertical-specific application issues that users should consider when evaluating the purchase of a robot.
“From a robot perspective, there are a lot more similarities than differences between verticals,” Brookshire said. However, the environment the robot will operate in can have as much of an impact on your selection as robot functionality.
“If handling any type of raw food or something not packaged is required,” said Brookshire, “then protected robots with an IP67 rating or higher will be required. You may also have to consider the robot’s ability to use food grade grease on any exposed axes. These are common requirements for robots that need to be washed down after use.”
Brookshire added that Epson deploys quite a few robots in environments where oil mist and/or metal or wood dust is in the air. “These are also cases where a protected robot would be suggested to make sure that the oil mist doesn't get to the interior of the robot,” he said. “But from the application perspective, the projects could be similar—like a simple material handling task—which could involve moving auto parts or food from point A to point B.”
Deciphering the robot types
With that advice in mind, I asked Brookshire to offer some basic guidelines for users to help them make sense of the variety of robot types available for industry, such as selective compliance assembly robot arm (SCARA), delta, cartesian and six-axis.
“SCARA and six-axis are the most popular” robot types, he said. “Delta and cartesian fit in more niche areas.”
For SCARA robots, it’s “all about speed and precision,” Brookshire said. “SCARA robots are able to handle small to mid-sized parts and move them very quickly with very high precision. Epson offers SCARA robots that feature repeatability down to 5 microns. SCARA robots also have a small footprint compared to cartesian robots. The limiting factor is that SCARA robots can only move components in an XYZ plus rotation orientation, in other words from a flat surface to a flat surface.” He added that SCARA robots also usually have “a very reasonable price.”
Six-axis robots are generally a bit slower and have less precision than SCARA robots, but the tradeoff is that “you get a robot with much more flexibility of motion, Brookshire said. “Movements and positioning can now occur in XYZ plus pitch, yaw and roll orientation. This means you can pick up something sitting at an angle and place it flat or vice versa. This flexibility is sometimes critical for specific applications.”
Video of Epson’s compact, six-axis Flexion N-Series Robots
For high-speed picking and placing applications where high precision is not required, such as in packaging or pulling parts off a moving conveyor, delta robots are the preferred choice. The limitations on these robots are their “amount of Z stroke, payload and precision,” Brookshire said. “Also the Z stroke varies as the robot moves further away from the center position. The other limiting factor is the mounting structure. It takes a very solid structure to hold reasonably sized delta robots.”
As for cartesian robots, Brookshire noted that there is a wide variety available. “Some are very high precision with linear motors and glass scale encoders. Others are made of simple air cylinders with very minimal precision. A limiting factor of cartesian robots is that they usually have to be assembled and they take up a large footprint compared to the other robot types.”
Programming
One issue with robots that users have complained about for years is their difficulty in programming. Since this aspect of robots is something collaborative robot developers have focused on simplifying, I asked Brookshire if the issue of robot programming is something robot manufacturers, in general, are looking to simplify.
Brookshire noted that simplified programming is a key aspect of collaborative robots because these types of robots are used to “simplify simple applications.” But if you speak with users trying to do more difficult robot applications with collaborative robots, he said that many of them are finding collaborative robots more cumbersome to use. “That’s because, in such applications, the simple user interface for collaborative robots goes out the window and you have to work in a scripting or typical programming environment, which can be more difficult to use than many of the other non-collaborative robot development environments,” he said.
Robot vendors are, however, taking note of the simplified programming associated with collaborative robots and “are working to build a simpler development environment or tools for simple applications,” Brookshire said. “In the case of Epson Robots, we have always been known for our ease of use, but this ease of use was built for what we consider normal applications—something that tends to be difficult for most collaborative robots. For simple applications, we have wizards and tools to help simplify common tasks or functions like creating pallets and defining tool offsets. Also, many robot vendors have a series of integrated options, like vision guidance, which provide total solutions rather than just a robot in a box.”
Brookshire explained that the “challenge of making things ultra-simple can sometimes mean that they can't be used for more difficult applications. But to require users who want to apply robotics in simple applications to have to use the standard robot toolsets makes things too difficult. Balance is required. Robot vendors are busy working on this now. I believe you will see more application-specific solutions as the industry moves forward, rather just looking at robots as motion devices.”
About the Author
 David Greenfield

 Leaders Logo
Leaders relevant to this article: